Project file项目档案 / 01

Table for Two

Embodied AIOpenVINO · MuJoCo · ACT2026

A contact-physics testbed for turning language into coordinated two-arm manipulation. The scripted pipeline completed 29/30 unseen scenes; the learned policy solved early stages but not the full chain.一个将语言转化为双臂协同操作的接触物理试验台。脚本管线在未见场景中完成 29/30;学习策略能完成前期阶段,但未打通完整链路。

Status状态
Solo hackathon prototype独立黑客松原型
Evidence证据
29/30 unseen scripted runs未见脚本运行 29/30
Learned policy学习策略
0/10 complete task完整任务 0/10
Runtime运行
Local Intel CPU / iGPU本地 Intel CPU / iGPU
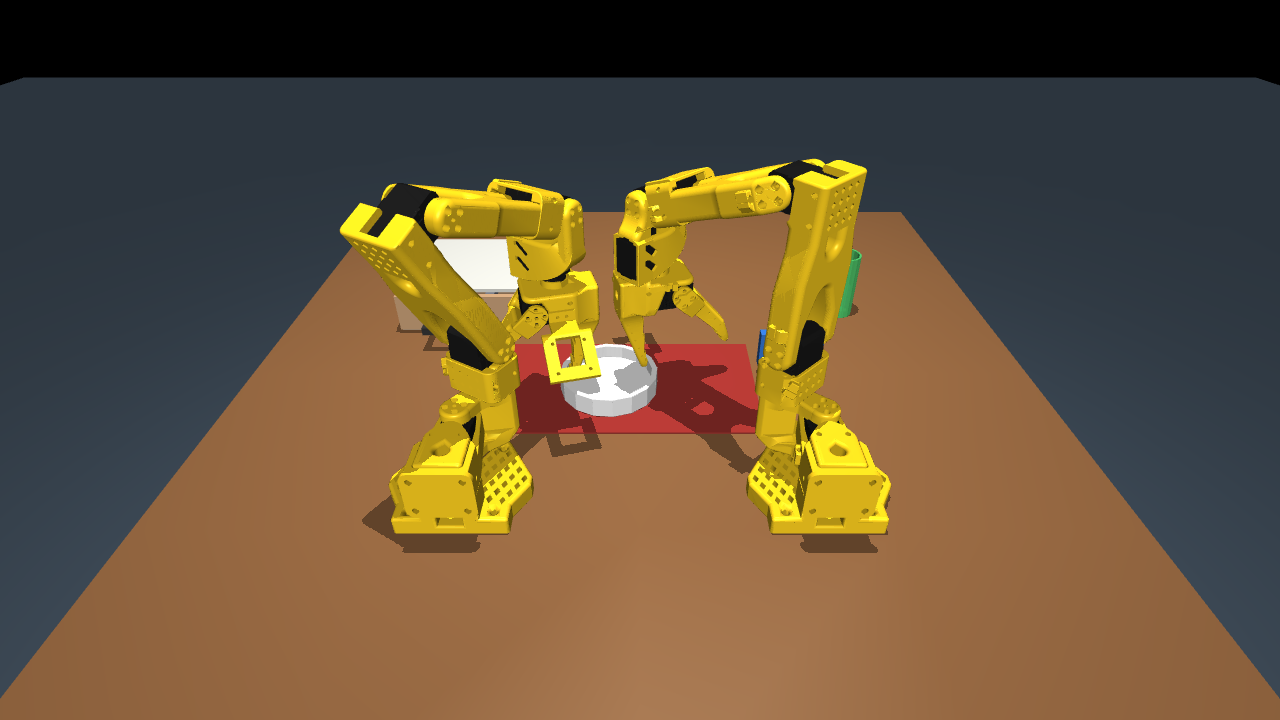
Table for Two — project visual

01 / Table for Two01 / Table for Two

From language.
Into action.
从语言,
到行动。

A real prototype. A testable claim.可运行的原型,可验证的主张。
Two simulated SO-101 robot arms setting a table 01
Approach & evidence方法与验证
Problem问题

Can low-cost home robots plan and execute two-handed everyday tasks on local hardware?低成本家用机器人能否在本地硬件上规划并执行双手日常任务?

My work我的工作

Language planner, validated task grammar, bimanual skills, contact tuning and evaluation scenes.语言规划、任务语法校验、双臂技能、接触参数调优与评估场景。

Proof验证

Physics-only manipulation, randomised scenes and OpenVINO inference without cloud or discrete GPU.纯物理操作、随机化场景,以及无需云端和独立显卡的 OpenVINO 推理。